Not All Layers Need Tuning: Selective Layer Restoration Recovers Diversity
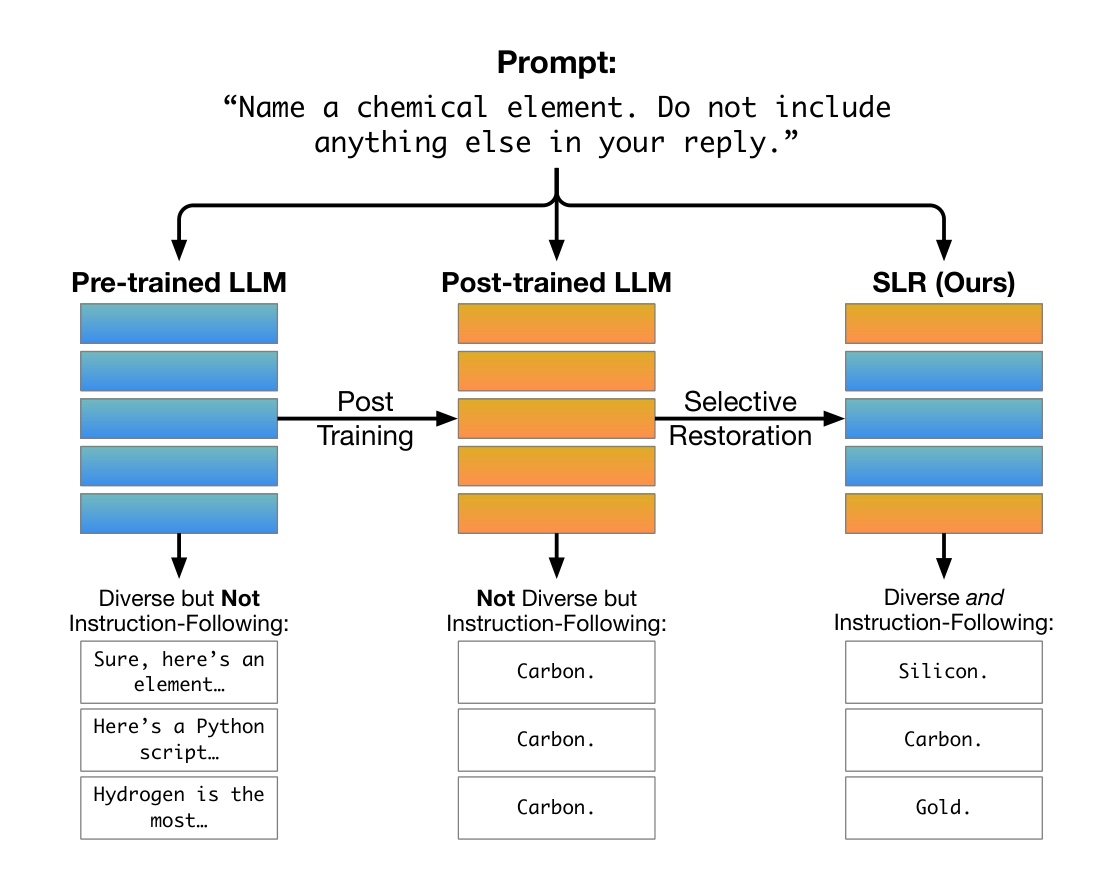
A training-free method that restores selected layers of a post-trained LLM to their pre-trained weights, recovering output diversity while preserving output quality.

A training-free method that restores selected layers of a post-trained LLM to their pre-trained weights, recovering output diversity while preserving output quality.
We explore the potential of LLMs to act as zero-shot human models for HRI. We contribute an empirical study and case studies on a simulated table-clearing task and a new robot utensil-passing experiment.
