APPL: Agent Priors-guided Policy Learning
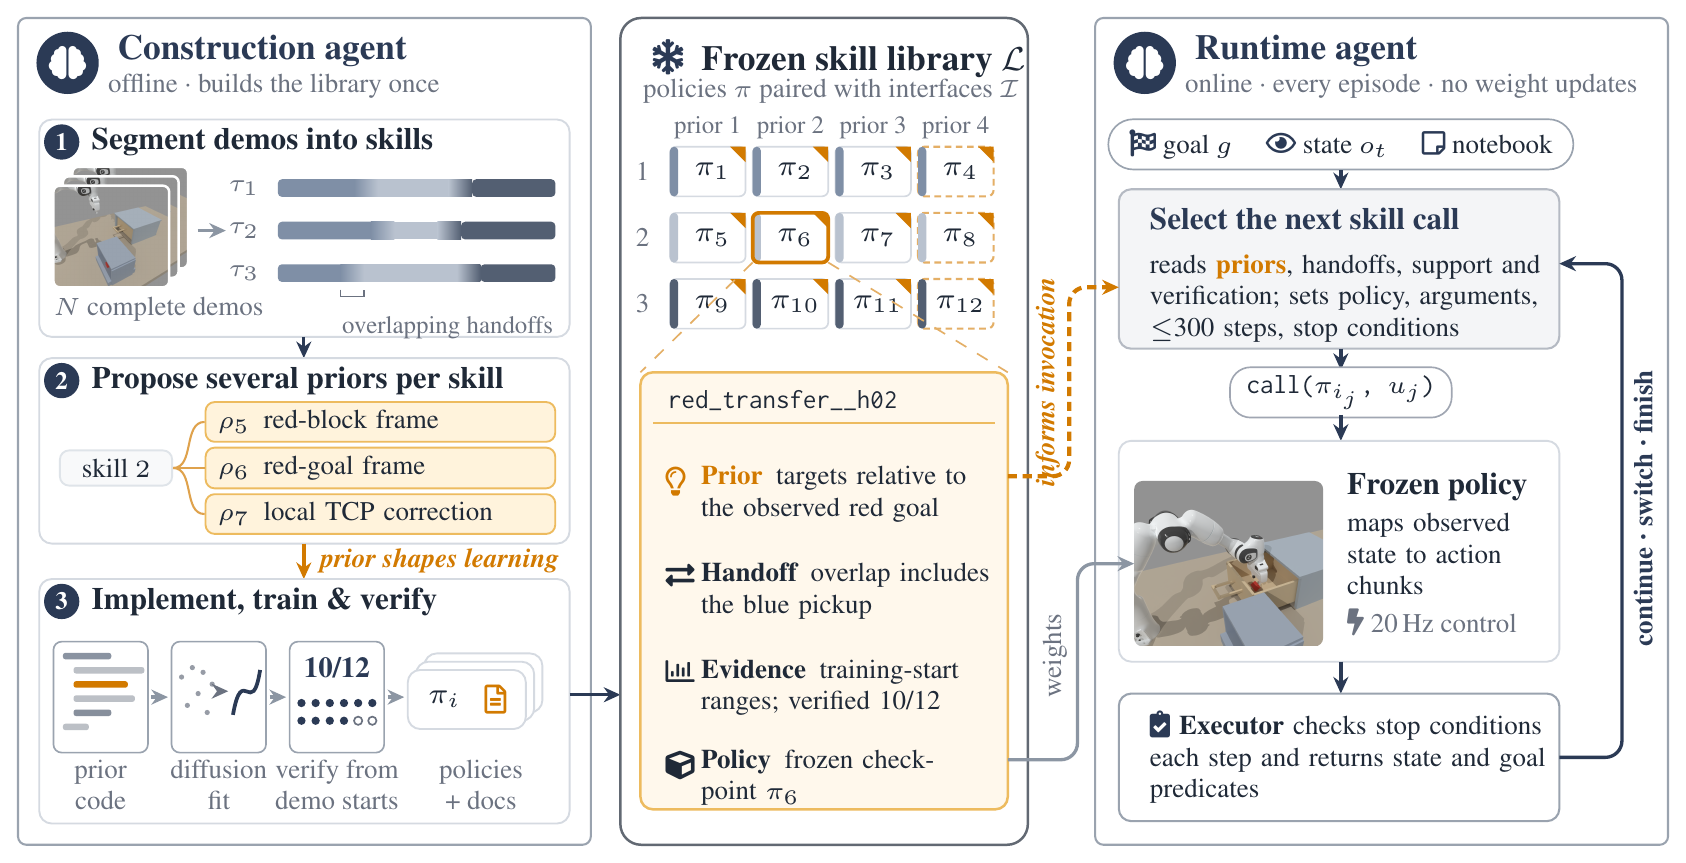
An agentic robot learning framework connecting policy learning with agent-based skill selection and composition through structural priors.
Powered by McDonald’s fries🍟
An agentic robot learning framework connecting policy learning with agent-based skill selection and composition through structural priors.
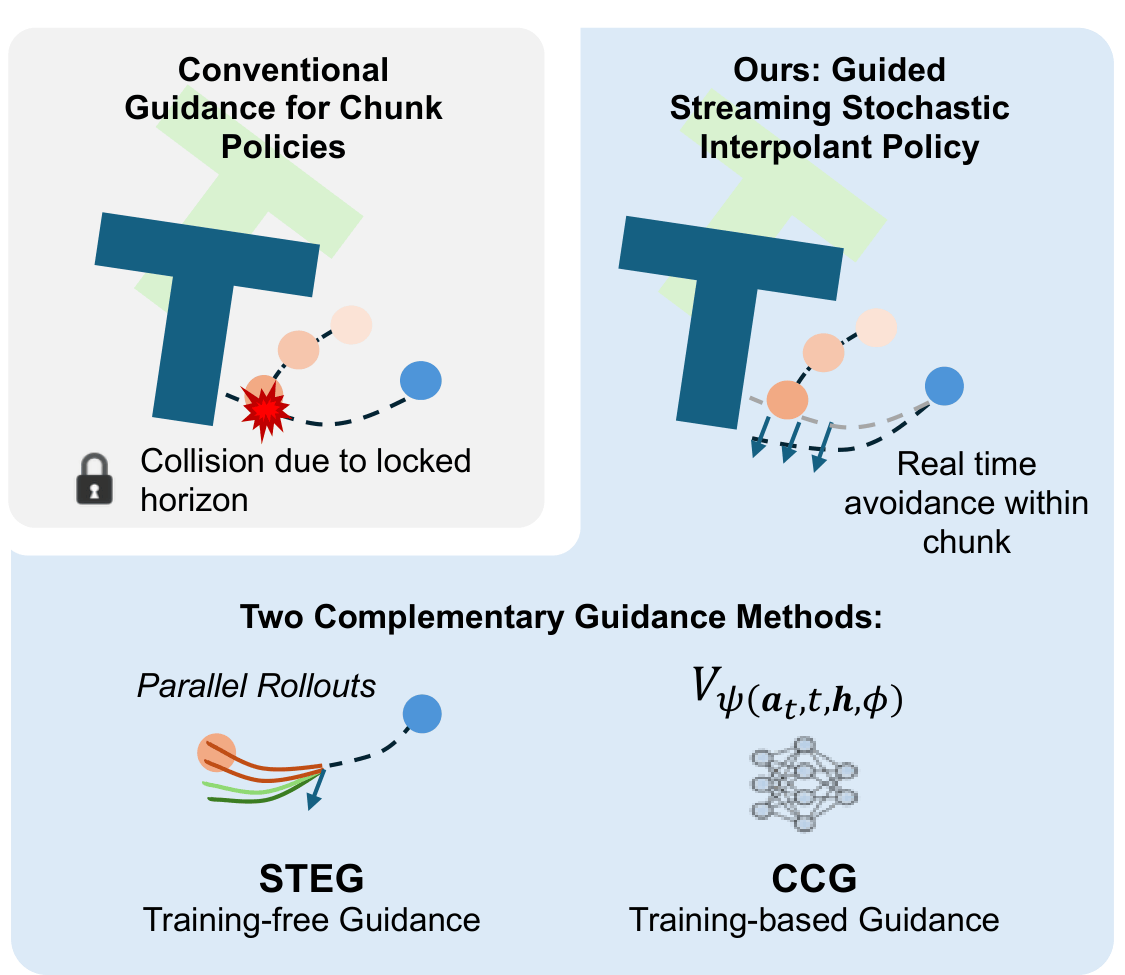
A principled inference-time guidance framework for streaming generative robot policies, enabling fast, reactive obstacle avoidance within the action chunk.