Early Career Spotlight at R:SS 2023!
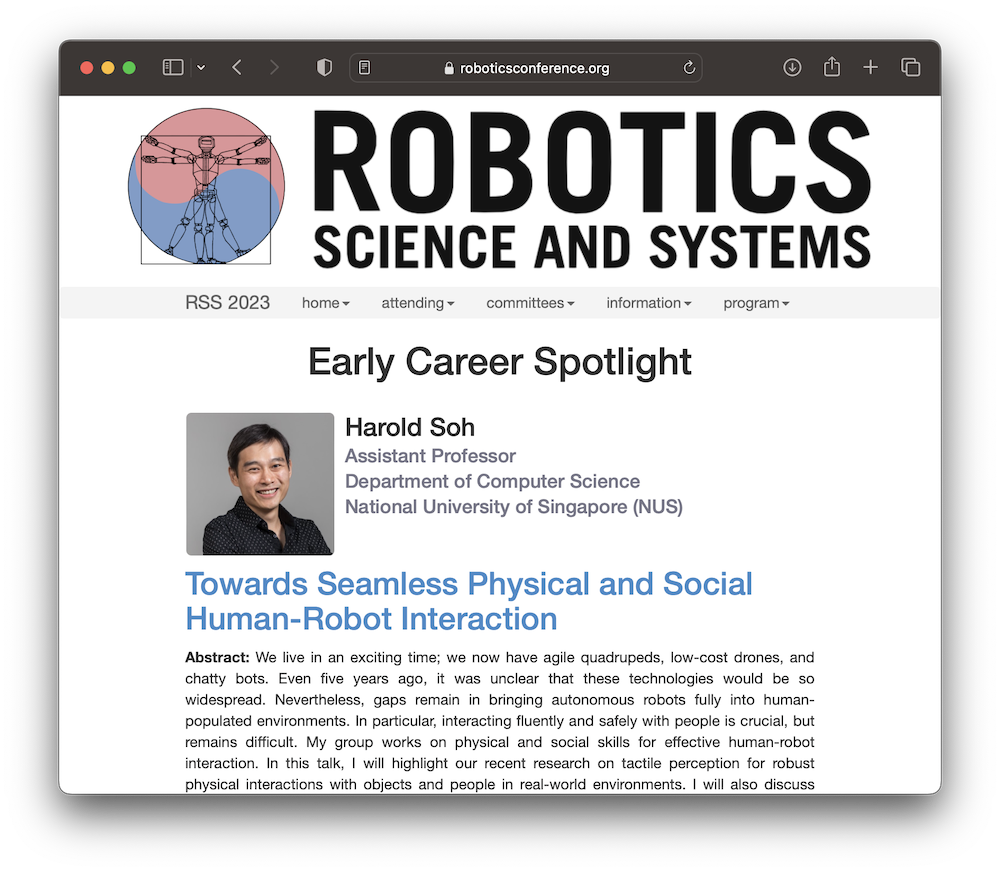
Harold has been awarded an Early Career Spotlight at the Robotics: Science and Systems 2023. The Early Career Spotlight “* acknowledges the outstanding acc...
Laruso blog features productivity, tips, inspiration and strategies for massive profits. Find out how to set up a successful blog or how to make yours even better!
Harold has been awarded an Early Career Spotlight at the Robotics: Science and Systems 2023. The Early Career Spotlight “* acknowledges the outstanding acc...
We develop a family of stable continuous-time neural state space-models.
Xie Yaqi successfully defended her thesis and is now Dr. Xie. Congratulations Yaqi! You can find out more about Yaqi’s work on embedding symbolic knowledg...
We contribute an empirical study into the effectiveness of LLMs, specifically GPT-3.5 variants, for the task of natural language goal translation to PDDL.
Transfer source policies to a target reinforcement learning task with safety constraints using Successor Features.
We examine the problem of observed adversaries for deep policies, where observations of other agents can hamper robot performance.
Our joint work with Desmond Ong, Jamil Zaki and Noah Goodman on Applying Probabilistic Programming to Affective Computing is one of 5 Best Papers (out of 82 ...