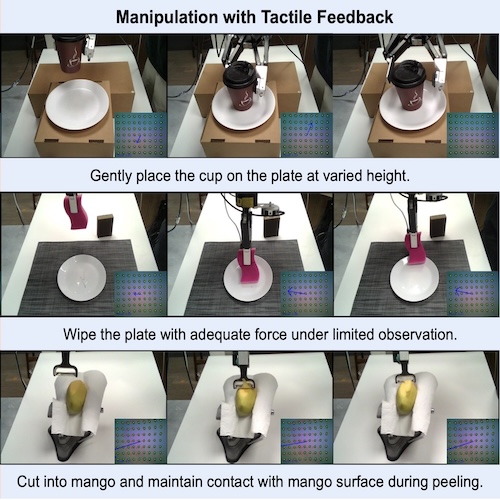
VLA-Touch: Enhancing Vision-Language-Action Models with Dual-Level Tactile Feedback
We present VLA-Touch, a framework for VLA models with dual-level tactile feedback for contact-rich manipulation.

Laruso blog features productivity, tips, inspiration and strategies for massive profits. Find out how to set up a successful blog or how to make yours even better!
We present VLA-Touch, a framework for VLA models with dual-level tactile feedback for contact-rich manipulation.
Congratulations to Tasbolat Taunyazov for winning the NUS School of Computing Best PhD Thesis Award in CS! The prize is awarded to “the most outstanding PhD ...
Harold gave a keynote at ICRA’25 on a foundation model for agents in embodied AI systems. Check it out below or on youtube: https://youtu.be/NCkwz0dBmO4?si=R...
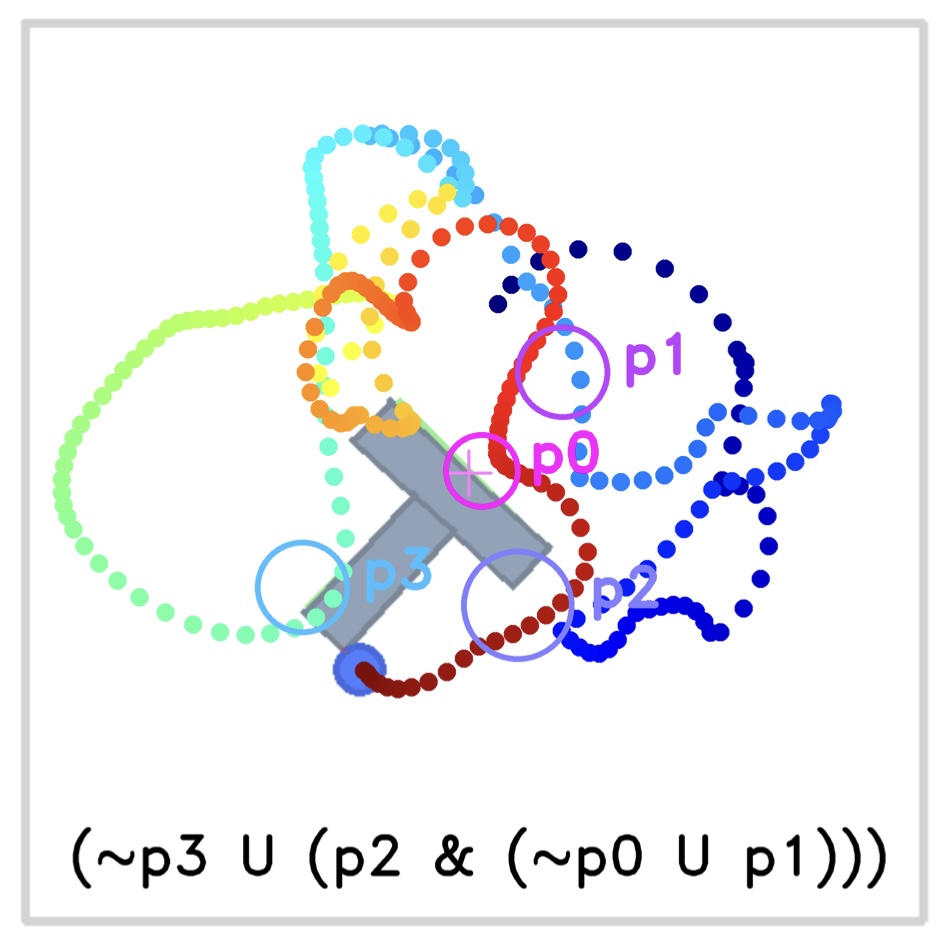
DOPPLER is a new framework that combines diffusion models and hierarchical reinforcement learning to let robots plan and replan complex, long-horizon tasks from offline data with robustness in the real world.
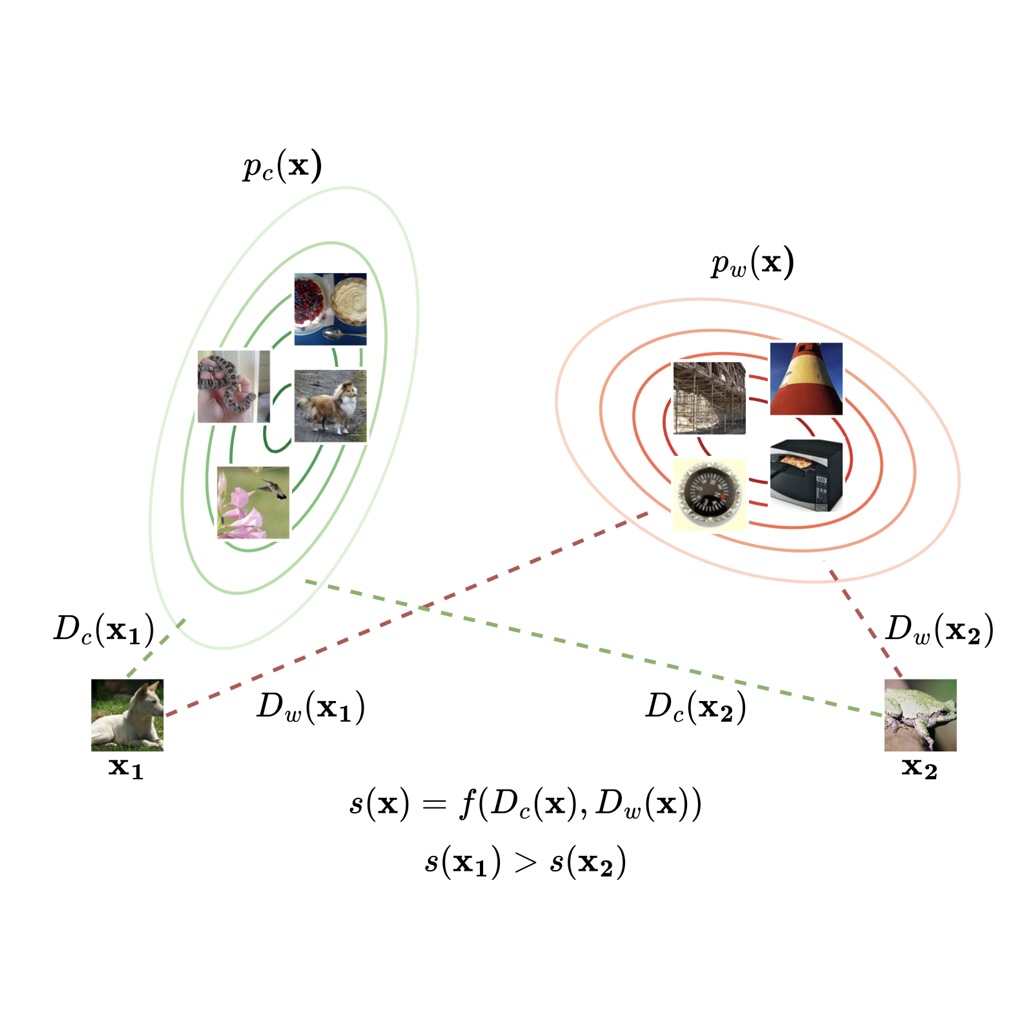
We propose optimal likelihood ratio-based selective classification methods based on the Neyman-Pearson lemma and evaluate them under vision and language covariate shifts tasks.
Kaiqi Chen successfully defended his thesis and is now Dr. Chen. Congratulations Kaiqi!
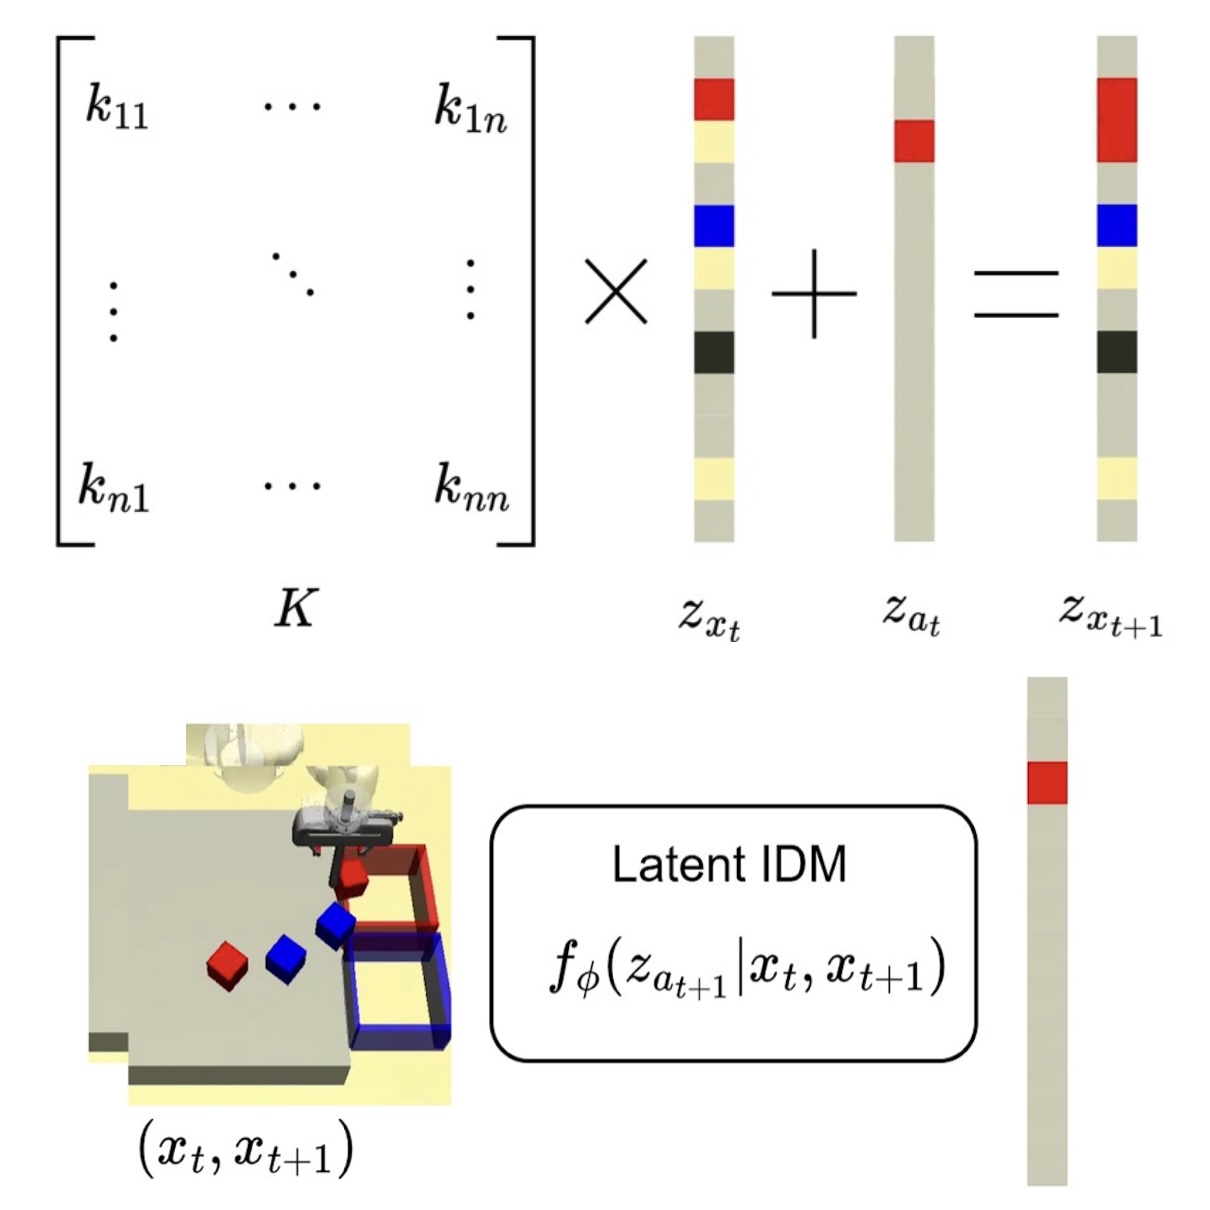
We introduce KOAP for imitation learning with limited actions.