CLeAR wins REAL-I 2026 Embodied AI Challenge!
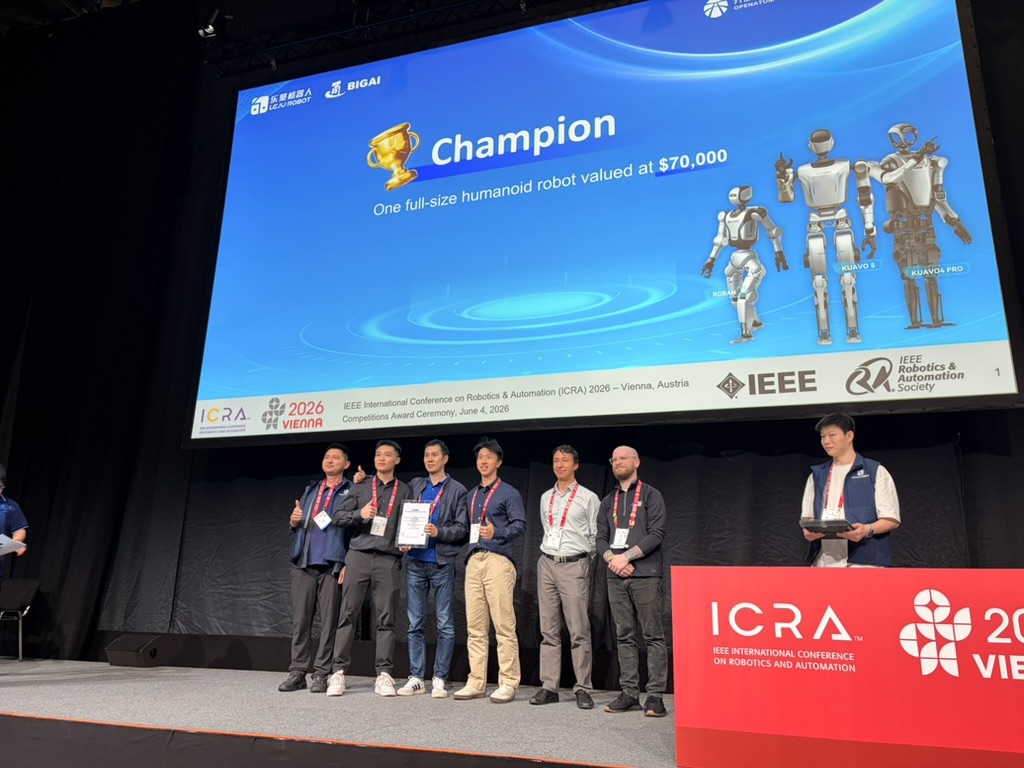
CLeAR took Overall Champion at REAL-I 2026, the 1st Real-World Embodied AI Learning Challenge, held at ICRA 2026.
Laruso blog features productivity, tips, inspiration and strategies for massive profits. Find out how to set up a successful blog or how to make yours even better!
CLeAR took Overall Champion at REAL-I 2026, the 1st Real-World Embodied AI Learning Challenge, held at ICRA 2026.
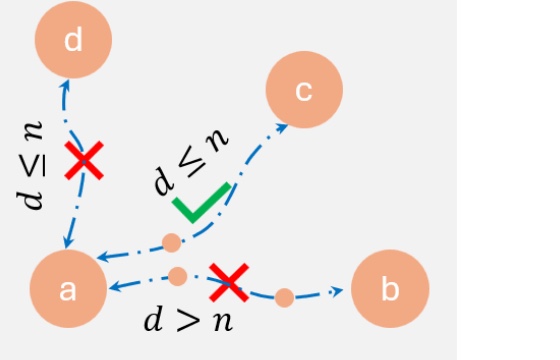
An open-source framework for evaluating topological mapping, with the first quantitative measure of dataset ambiguity (perceptual aliasing).
We are excited to share that a paper from CLeAR has been accepted to ICML 2026! Here’s a snapshot: Conflict-Aware Additive Guidance for Flow Models under Co...
We are excited to share that two papers from CLeAR were accepted to R:SS 2026! More information about the papers is coming soon, but here’s a snapshot: ...
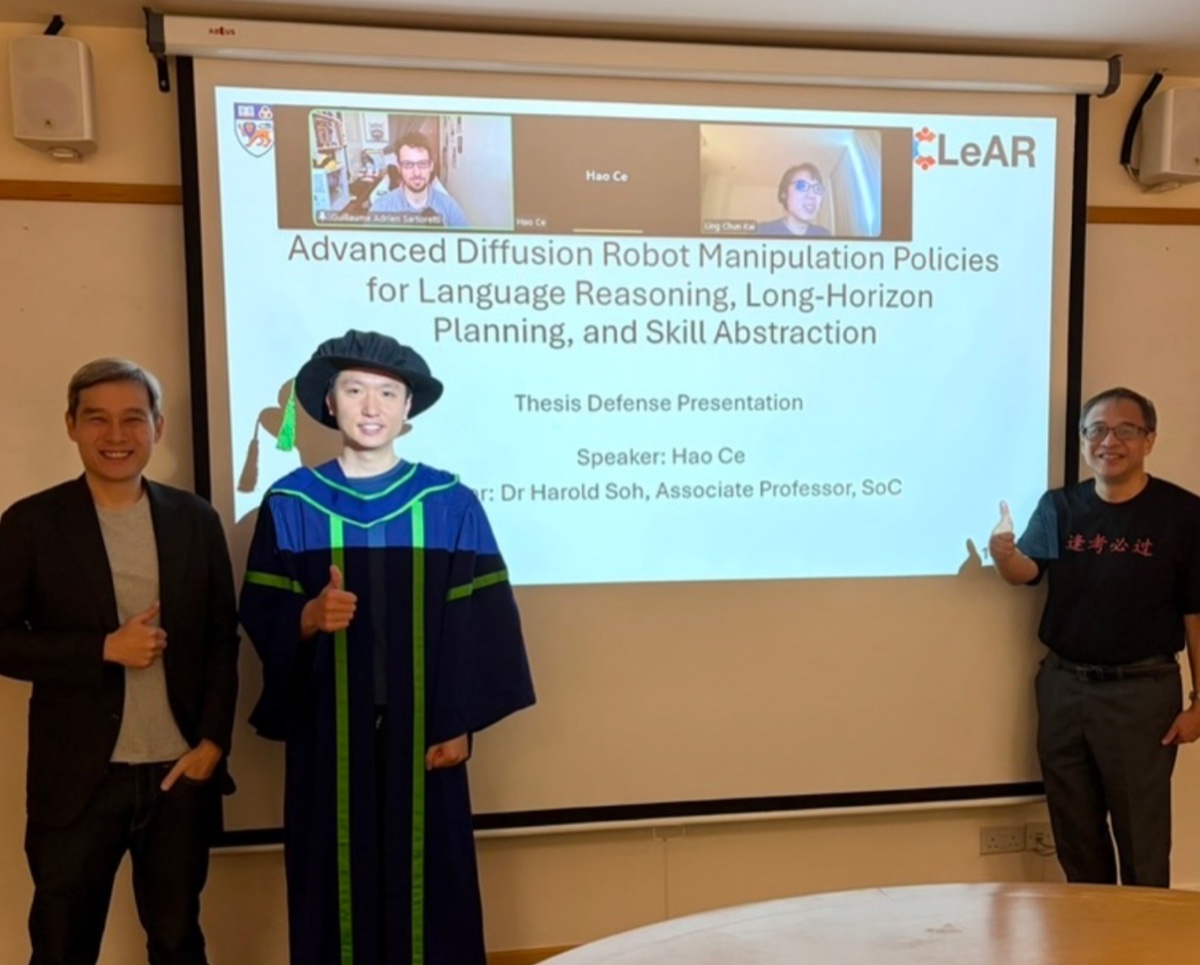
Ce Hao has graduated and is now Dr. Hao. Congratulations Ce! Ce’s PhD thesis, Advanced Diffusion Robot Manipulation Policies for Language Reasoning, Long-Ho...
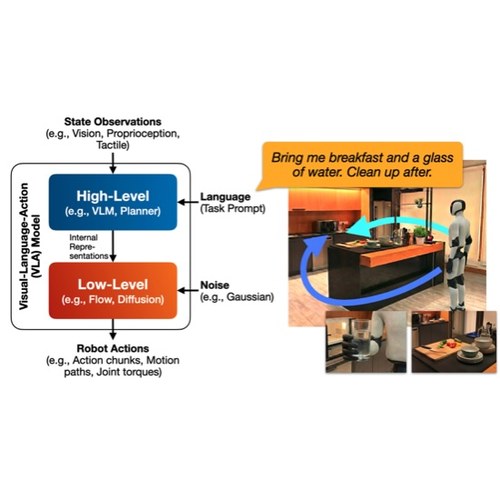
A theoretical analysis of why generative VLAs produce physically infeasible actions, identifying topological, precision, and horizon barriers that impose unavoidable tradeoffs.
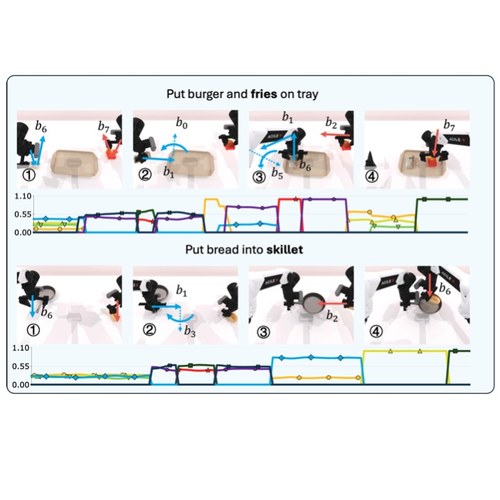
Skill Mixture-of-Experts Policy (SMP)—a diffusion mixture-of-experts policy that learns a compact orthogonal skill basis and uses sticky routing for scalable, efficient multi-task manipulation.